srvo

Push  Automotive range-extension R&D

Electric Pusher Trailer

Control algorithms for an electric trailer that extends a vehicle's range without hurting its handling, developed on a 1:10 scale rig.

AutomotiveRobotics
1:10
scale model SUV and chassis dyno for empirical modeling
3-axis
decoupled force sensing in the tow hitch
DYNO · 1:10
Driver GUARD OK
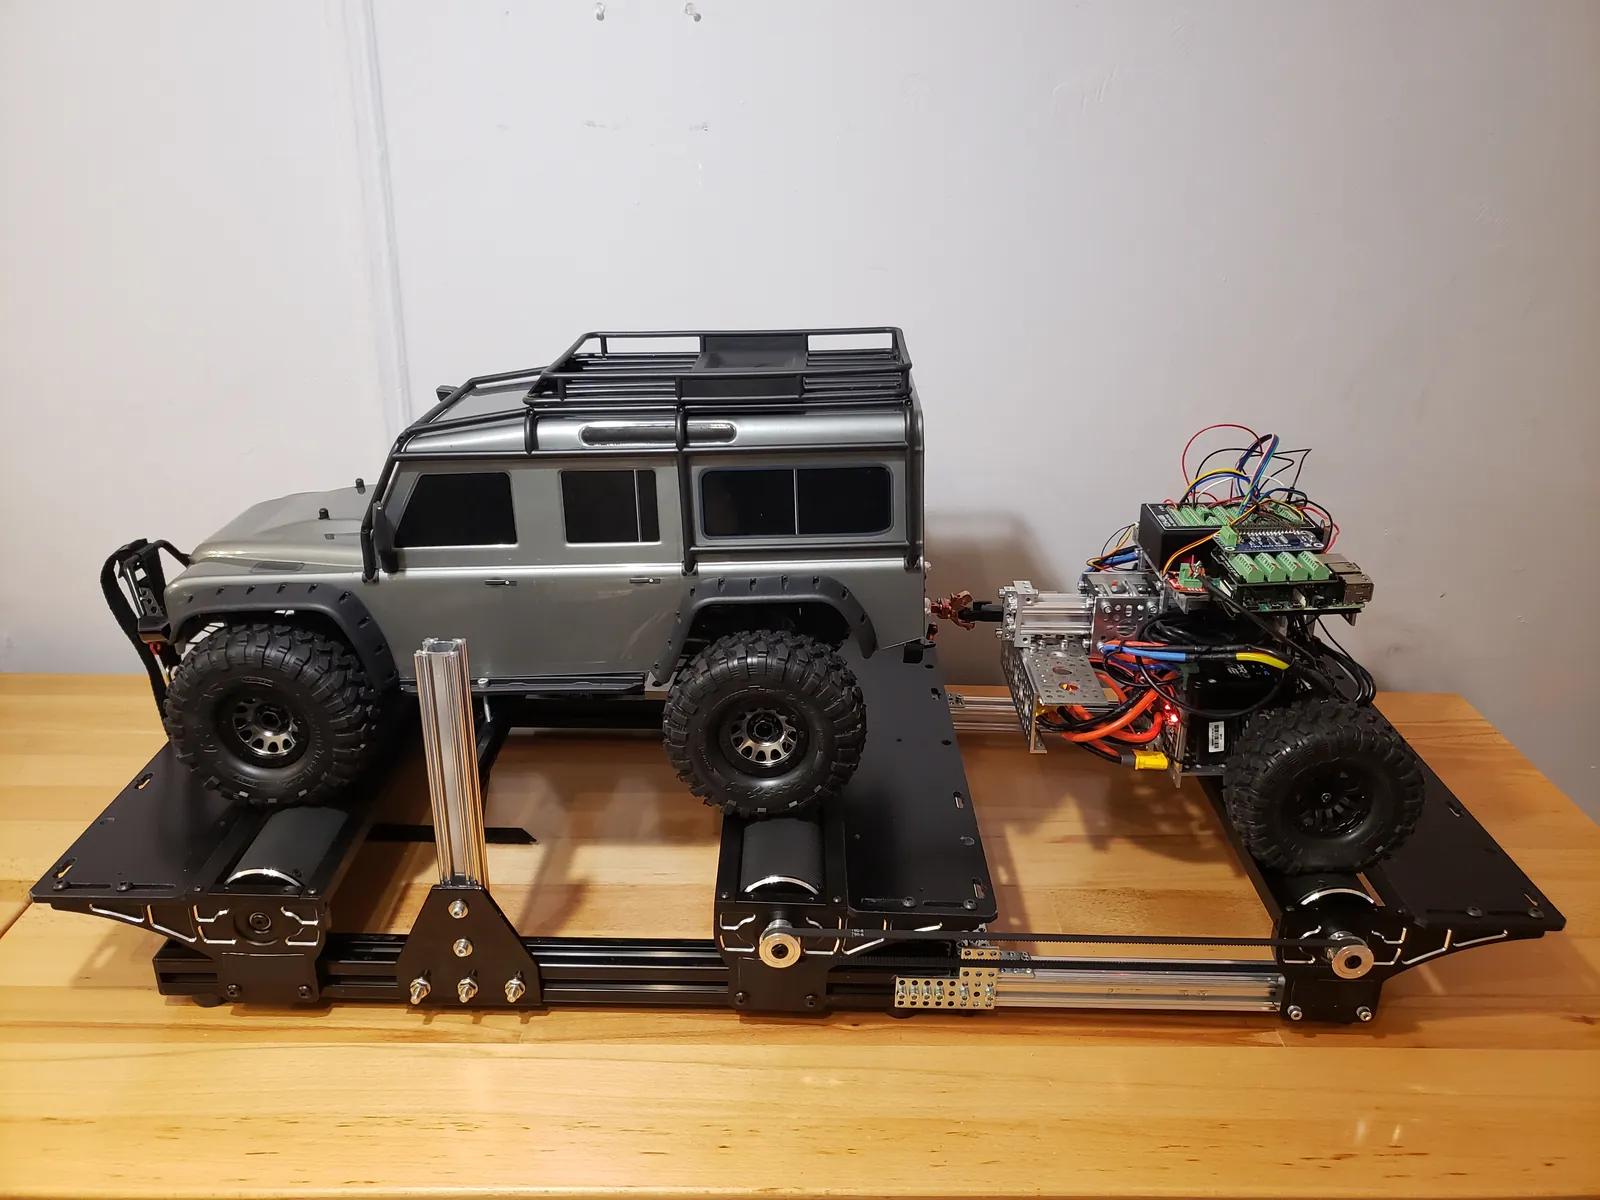
hitch force per axis (Fx, Fy, Fz) Fy trace guard limit ±9° lit load cell = axis carrying the load A 1:10 model SUV runs on a roller chassis dyno while a trailer robot pushes from behind. The hitch carries one load cell per axis on nested linear bearings, so each force is read on its own; those signals are the controller's primary input for driver intent, rollover and jack-knife detection, and the trailer's field-oriented-control motor answers over CAN. Forces, angles and assist shown here are simulated to illustrate the loop.

Challenge

Design an electric trailer that extends a vehicle’s travel range without adversely affecting how the vehicle handles.

Approach

We fitted a 1:10 scale model SUV and a chassis dyno with a sensor suite to build an empirical model, then built a trailer robot to develop control algorithms for safety and efficiency. Field-oriented control (FOC) runs on a customizable electronic speed controller. A touchscreen workstation handles parameter tuning, data logging and web dashboards. The model’s results drove sourcing of the full-scale trailer’s powertrain and suspension, paired with a multi-pack battery system built from OEM EV modules.

Highlights

  • A weight-distribution hitch with decoupled 3-axis force sensing and torque isolation through linear bearings mounted one within another.
  • Hitch load-cell signals are the primary feedback input for sensing driver intent, detecting rollover and preventing jack-knifing.
  • Drive-by-wire feedback control over CAN closes the loop on those load cells.
From the bench

1:10 scale model SUV on a roller chassis dyno, towing an instrumented trailer robot with exposed controller boards and wiring.
Ask an engineer